EtherNet/IP PLC Communication: Setup, RPI and Faults
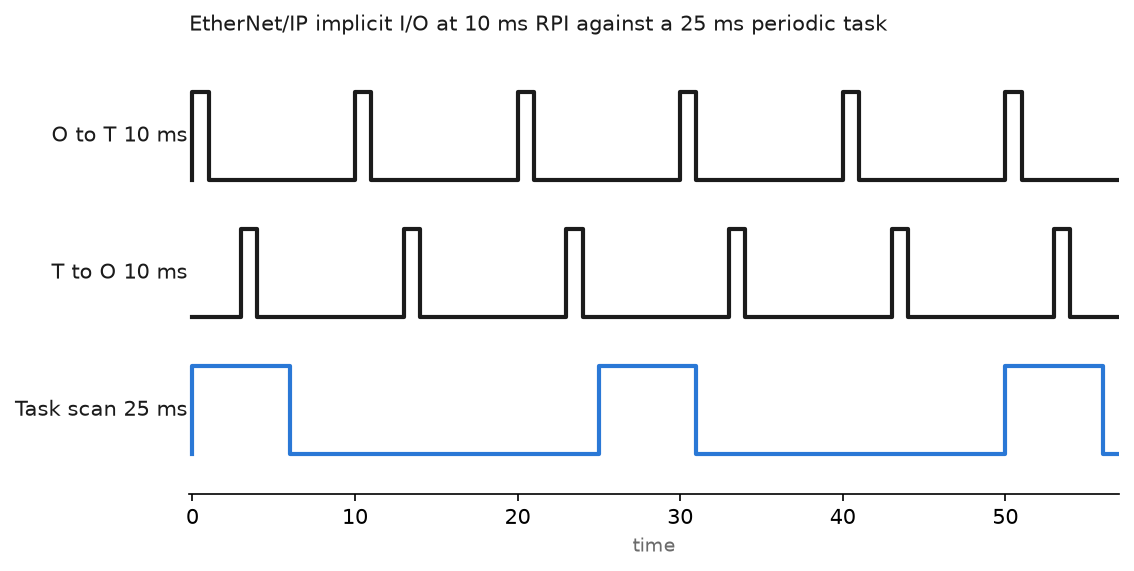
Set up EtherNet/IP between a Logix controller, remote I/O and a drive: RPI, unicast vs multicast, MSG paths, and the fault codes you will really see.
Set up EtherNet/IP between a Logix controller, remote I/O and a drive: RPI, unicast vs multicast, MSG paths, and the fault codes you will really see.
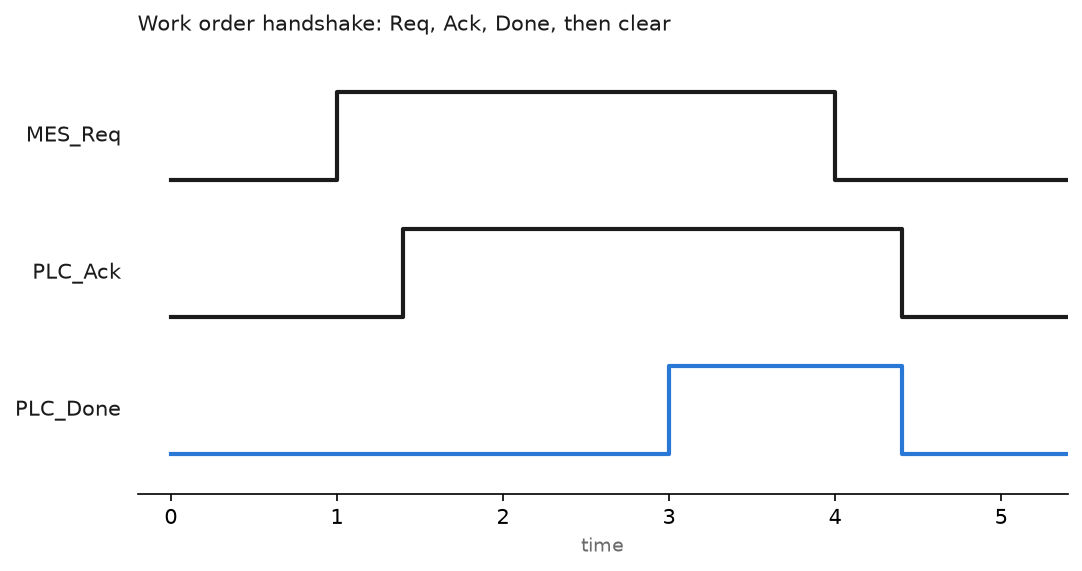
What MES really needs from the controller: OEE counters, downtime reason codes, a work order UDT, a request and acknowledge handshake, an OPC UA bridge.
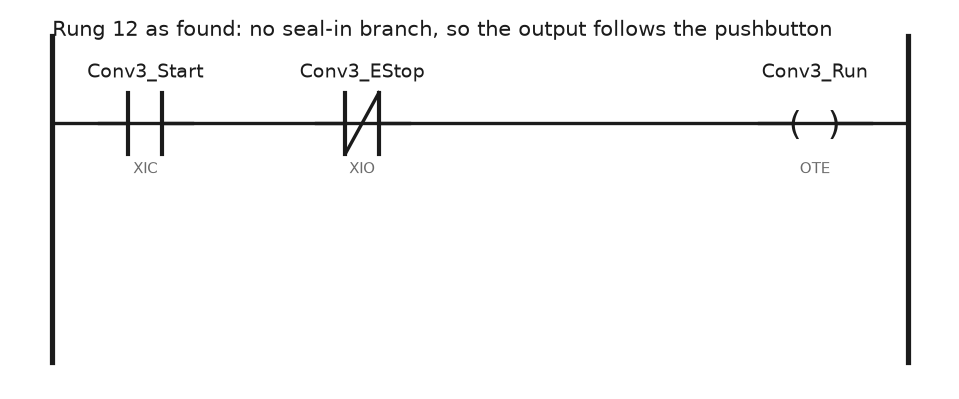
A rung by rung ControlLogix ladder troubleshooting method: read the highlighting, use cross reference and search, find double coils, read the fault record.
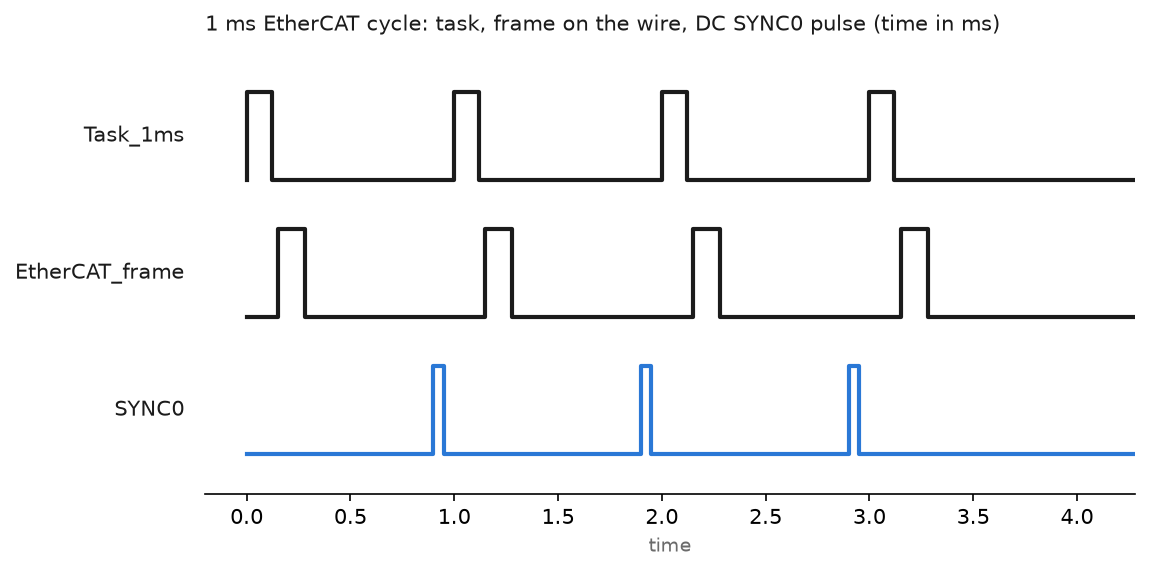
Set up an EtherCAT bus in TwinCAT 3: ESI files, scanning the line, picking a cycle time, distributed clocks and the CRC counters that find a bad cable.
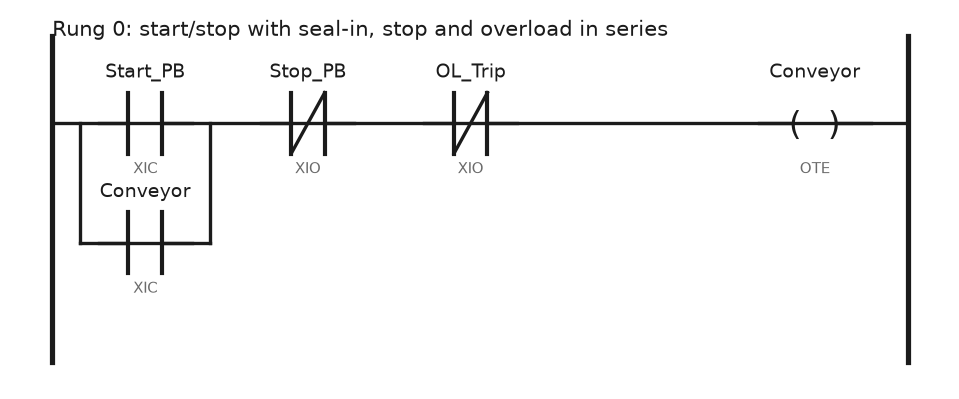
PLC programming for beginners without the theory dump: pick a simulator, write a start/stop rung, add a timer and a counter, wire one HMI button.
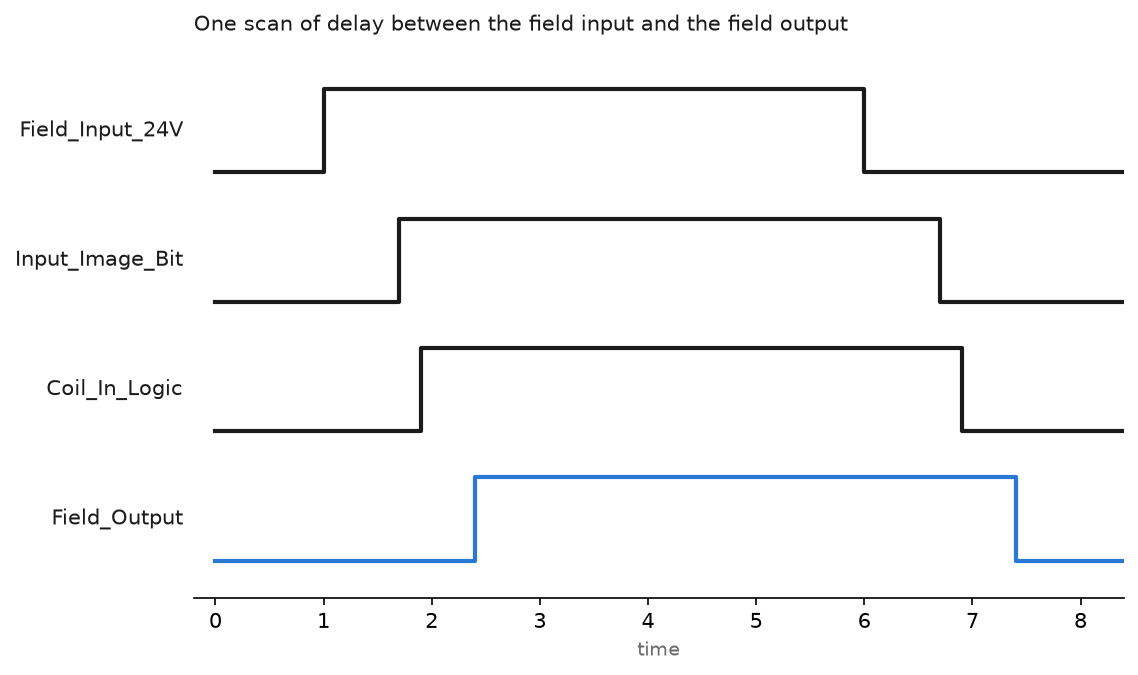
What is in a PLC rack and how the software sees it: power supply budget, CPU memory, I/O cards, tasks and routines, and tags against S7 addresses.
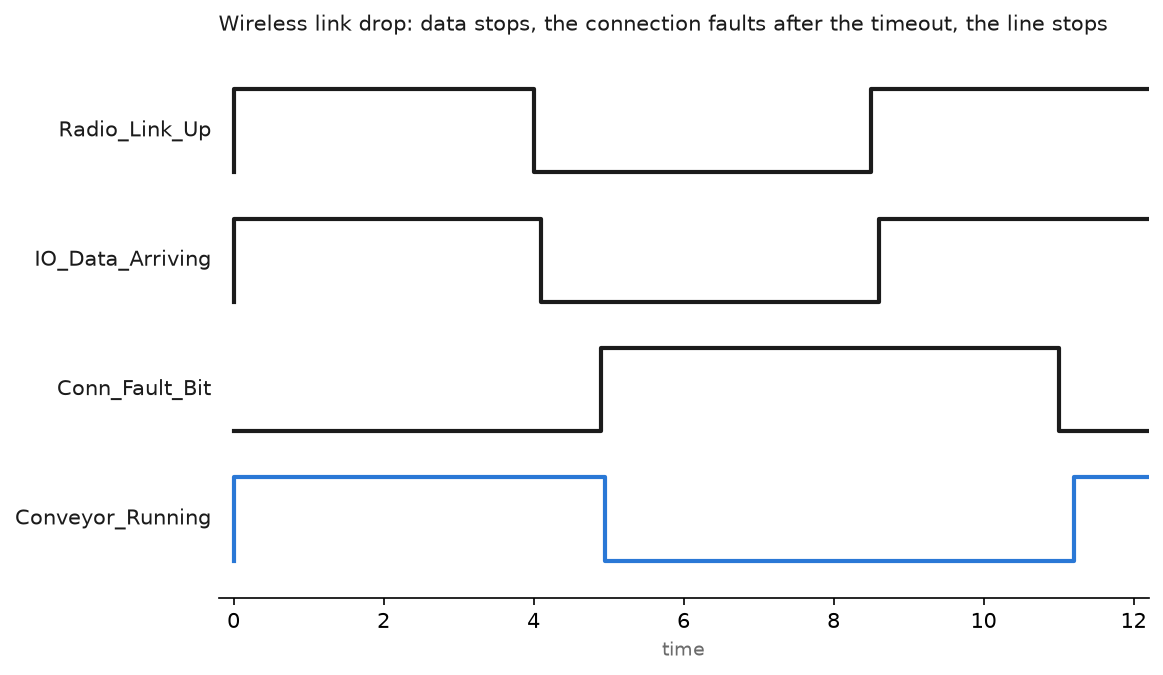
Wireless PLC communication done properly: choosing Wi-Fi, 900 MHz radios or cellular, RPI and timeout budgets, antennas, roaming, and link loss logic.
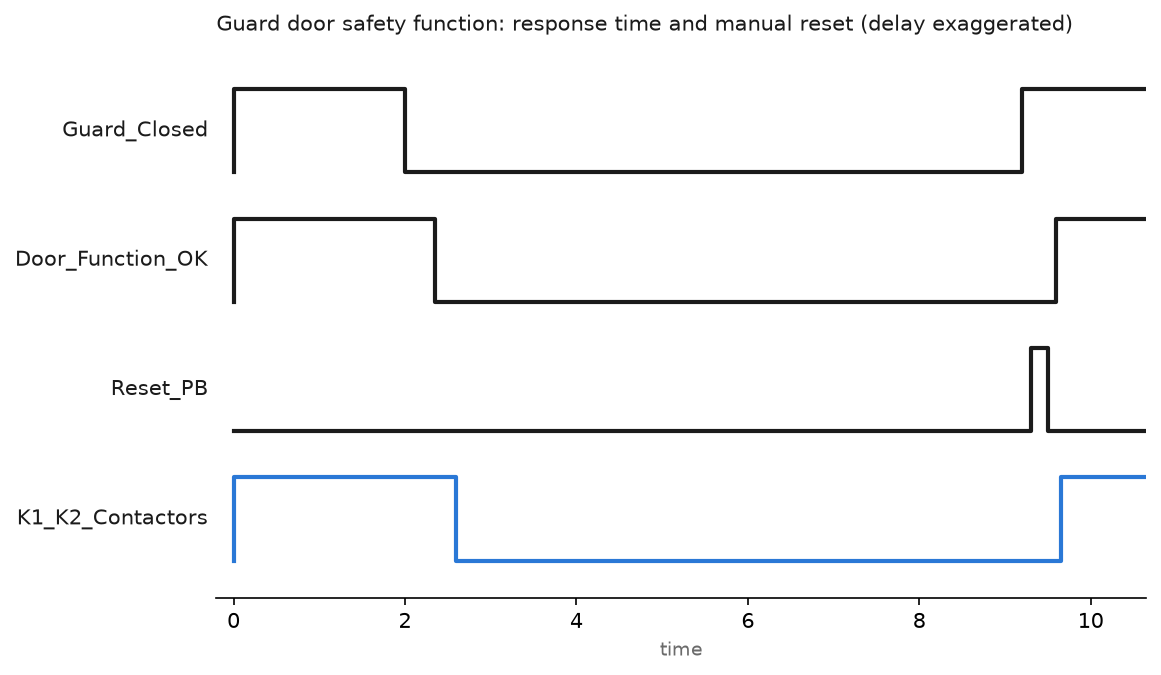
How functional safety works on a PLC job: the ISO 13849-1 risk graph, PLr, category 3 architecture, MTTFd, DC, CCF, a PFHd budget and SISTEMA.