Registration and the MAR Instruction: Catching a Mark at Speed on a Kinetix 5700
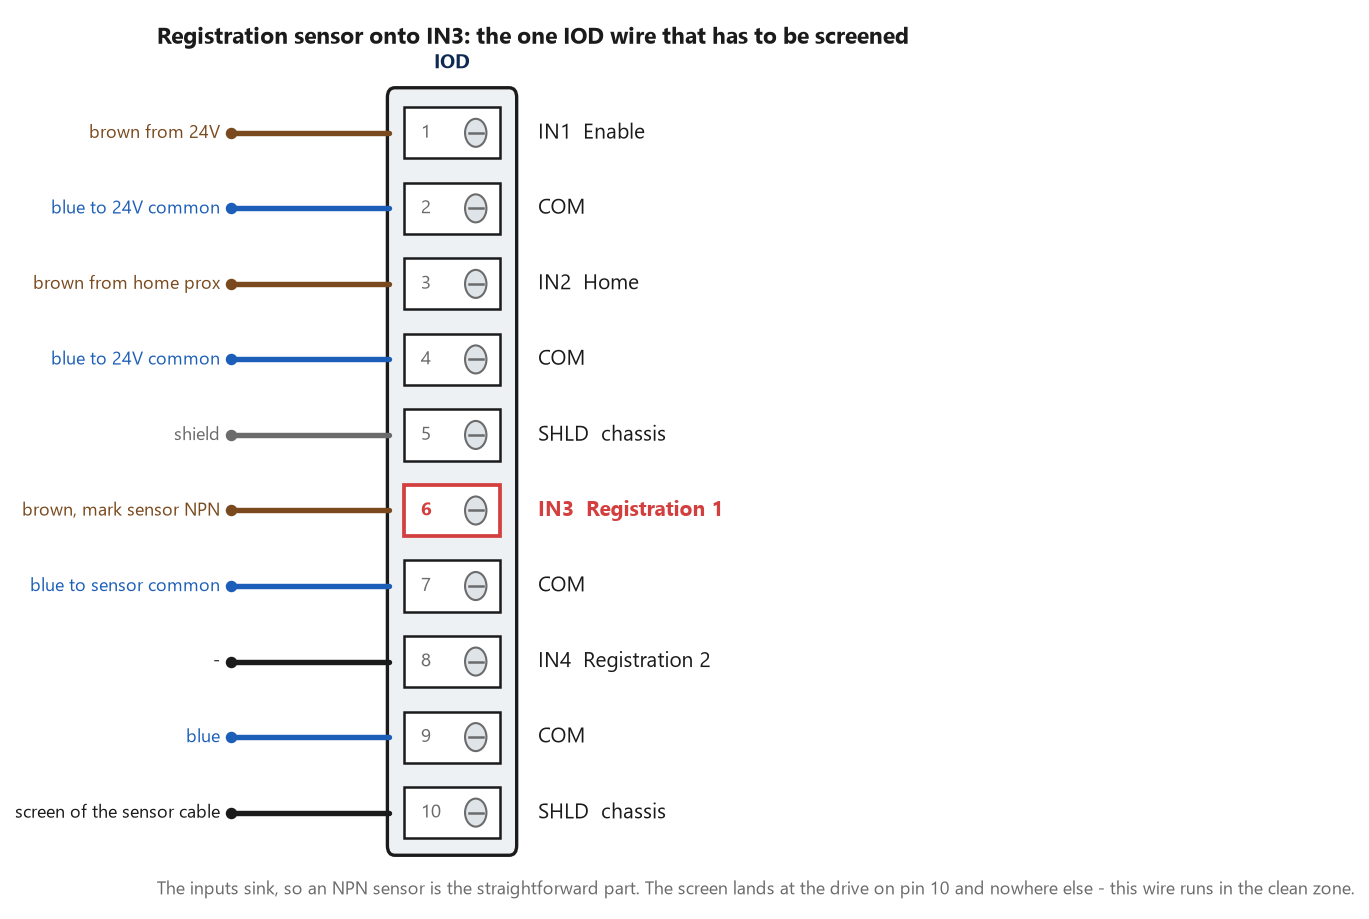
IOD connector of a 2198-D032-ERS3 drawn as a ten-terminal strip with the registration sensor on pin 6, IN3, the sensor common on pin 7 and the cable screen landed on pin 10, alongside the Enable and Home inputs on pins 1 and 3

Registration and the MAR Instruction: Catching a Mark at Speed on a Kinetix 5700 A Kinetix 5700 inverter latches a registration event with ±3 µs accuracy and 700 ns repeatability, and its propagation delay is compensated to zero. At 1.5 m/s that accuracy figure is 4.5 µm of position uncertainty. The photoeye in front of … Read more
Soft Travel Limits, Hard Limits and the Overtravel That Faults a Kinetix Axis

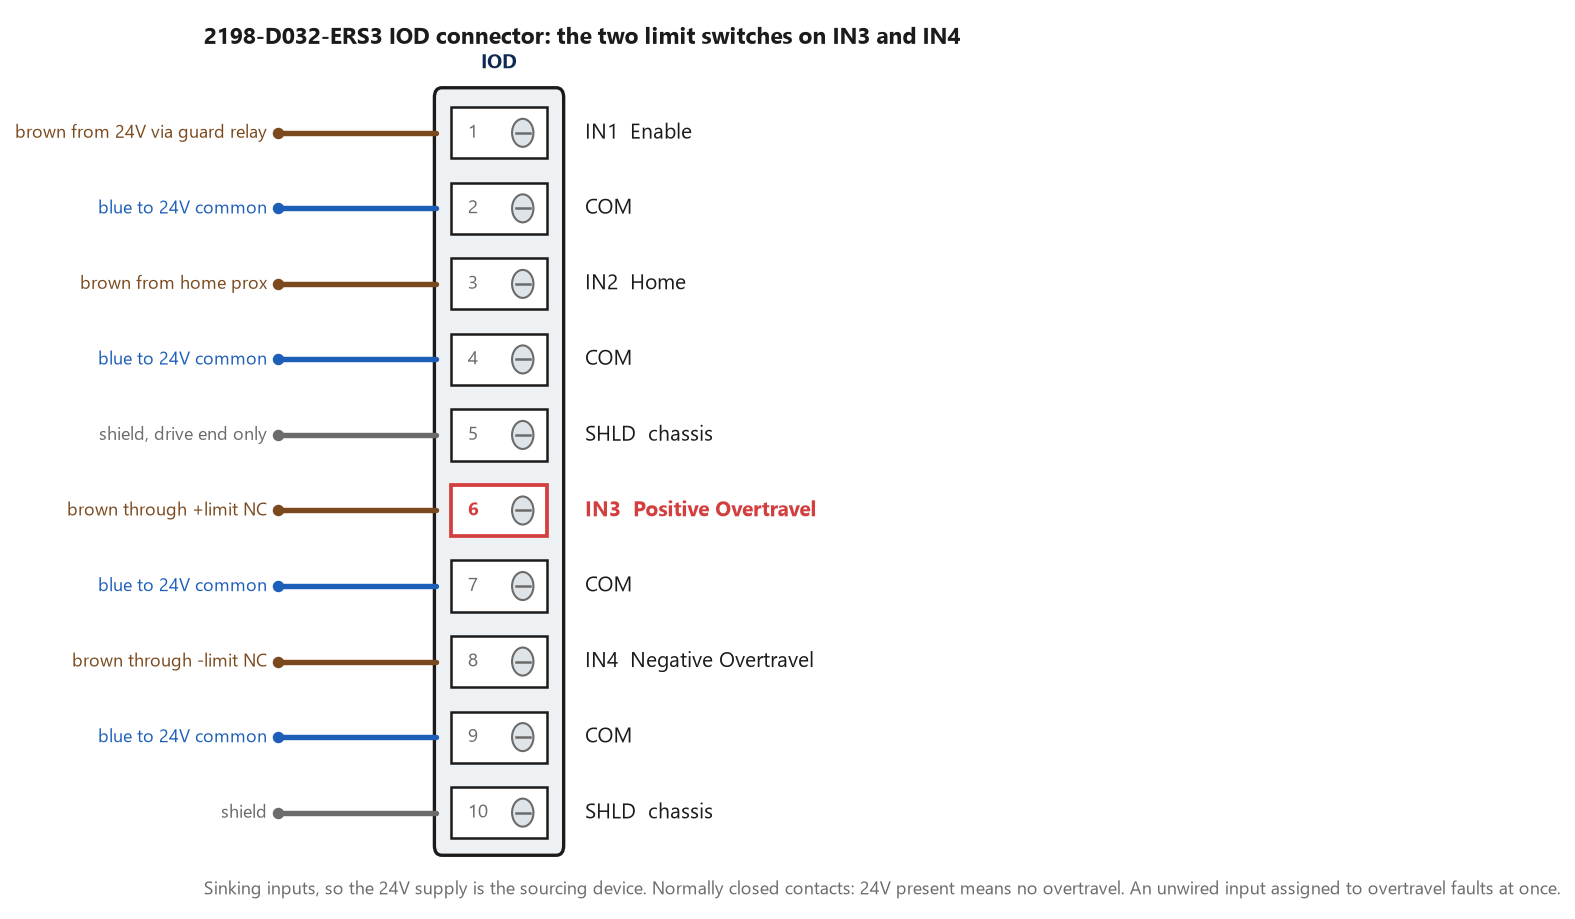
IOD connector of a 2198-D032-ERS3 drawn as a ten-terminal strip: IN1 Enable on pin 1, common on 2, IN2 Home on 3, common on 4, shield on 5, IN3 Positive Overtravel on 6 wired through a normally closed plus limit, common on 7, IN4 Negative Overtravel on 8 through a normally closed minus limit, common on 9, shield on 10

Soft Travel Limits, Hard Limits and the Overtravel That Faults a Kinetix Axis A registration input on a Kinetix 5700 inverter gets a 12.0 µs pulse reject filter. The overtravel input, on the same IOD connector and the same silicon, gets the 20 ms nominal debounce that every other input function gets. At 500 mm/s … Read more

Tuning a Kinetix 5700 Axis: Load Ratio, Bandwidth and the Autotune That Lies

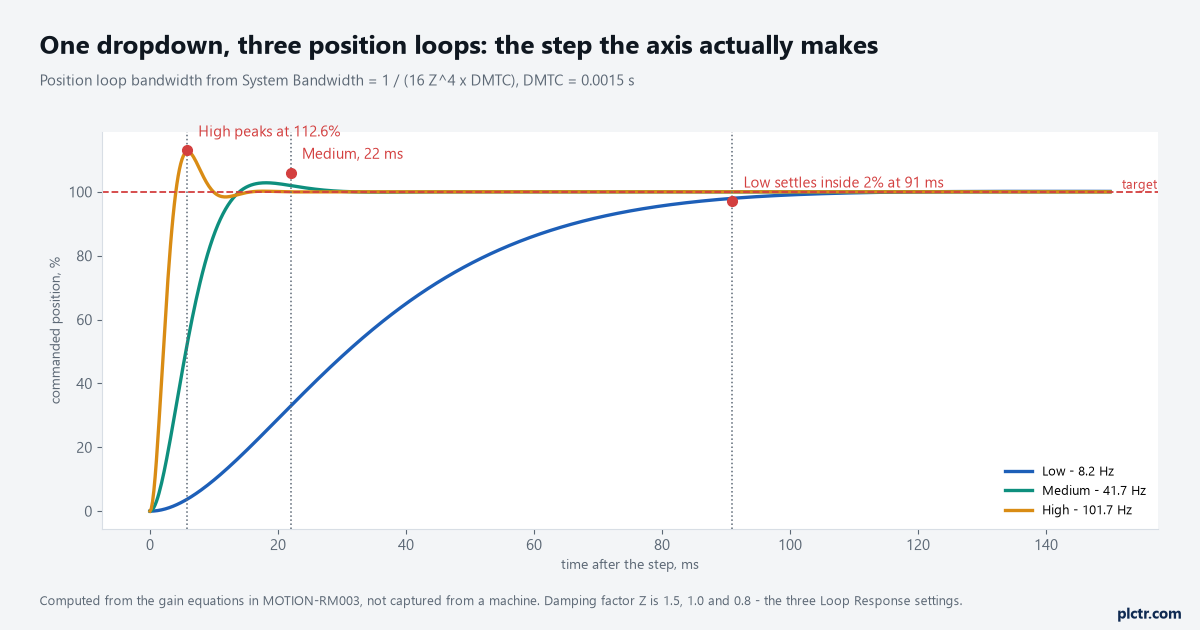
Step response of the same position loop at three bandwidths: 8.2 Hz settling inside two percent at 91 ms, 41.7 Hz at 22 ms, and 101.7 Hz peaking at 112.6 percent before settling at 9 ms, all against a target line at 100 percent

Tuning a Kinetix 5700 Axis: Load Ratio, Bandwidth and the Autotune That Lies Loop Response on the General page of a Kinetix axis is a three-item dropdown, and on a drive with the default 1.5 ms model time constant it moves the position loop between 8.2 Hz and 101.7 Hz. That is a factor of … Read more

Driving a Motor from a ControlLogix: From a Rung to a Turning Shaft on a Kinetix 5700

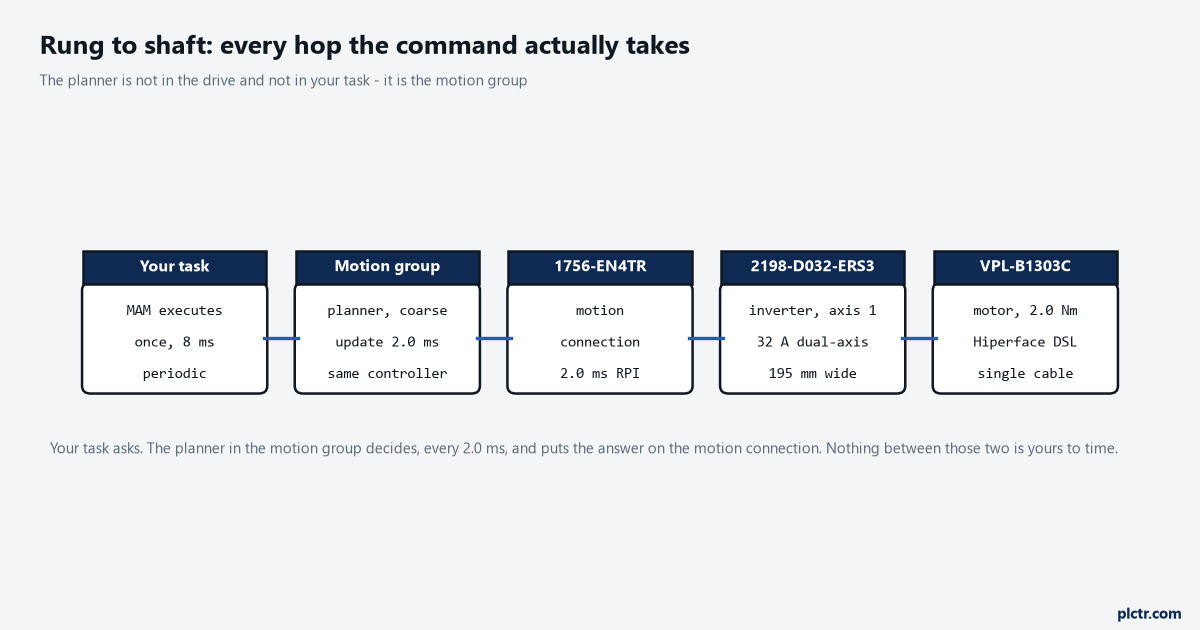
Five boxes left to right: Your task with MAM executing once in an 8 ms periodic task, Motion group with the planner and a 2.0 ms coarse update in the same controller, 1756-EN4TR carrying the motion connection at a 2.0 ms RPI, 2198-D032-ERS3 inverter axis 1 rated 32 A, and a VPL-B1303C motor at 2.0 Nm on a single Hiperface DSL cable

Driving a Motor from a ControlLogix: From a Rung to a Turning Shaft on a Kinetix 5700 A 2198-D032-ERS3 inverter, a VPL-B1303C motor on one Hiperface DSL cable, and a 1756-L83E that has never carried a motion group. Two rungs will turn that shaft — an MSO and then an MAM — and neither is … Read more

Advertisement